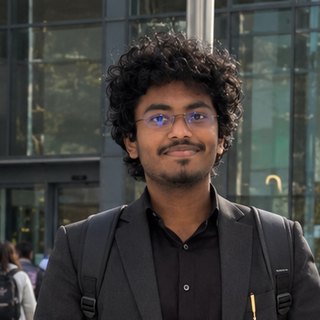
Portrait of Samuel Wesley Mondal

Mechanical Engineer

Dublin, Ireland · MEng, DCU

Open to internships & placements

Samuel Wesley Mondal

I simulate it, then I build it — and find out whether the simulation was right.

MEng in Simulation-Driven Design at Dublin City University. Wind-energy aerodynamics, UAV propulsion and functional 3D printing — and I founded and captained a 20-person drone team through national competitions.

Scroll
  • No. 2National rank, twice — CAM (2024) and 3D printing (2023), SAEISS NLSC
  • 1stBest Payload Mechanism Design — ADDC 2025
  • 20Engineers in the UAV team I founded and captained
  • First ClassBE Mechanical Engineering, LICET — 2025
01

How I work

Simulate → Build → Validate

Every project on this page runs the same loop. The interesting engineering is in the last step — the gap between what the model promised and what the hardware actually did.

  1. 01 — Simulate

    Model it first

    Work out the aerodynamic, structural or electrical behaviour before anything is cut, printed or wired. Cheap iterations happen here.

    Where I've done it

  2. 02 — Build

    Put it in your hands

    CAD to physical part: additive manufacturing, fabrication, wiring, assembly. A design that can't be built isn't a design yet.

    Where I've done it

  3. 03 — Validate

    Find out where it lied

    Test rigs, wind tunnels, instrumented flights. Measure the real thing and compare it honestly with the prediction.

    Where I've done it

02

Selected work

4 case studies
01 U∞ ω R λ = ωR / U∞

Wind energyJan – Apr 2026

H-type Darrieus vertical-axis wind turbine

Designed, analysed and optimised a straight-bladed Darrieus rotor, then took it into a wind tunnel. Two objectives: maximise power output under varying loads, and minimise the deviation between predicted and measured performance.

Scope
Design · analysis · optimisation · test
Validation
Wind-tunnel experiments
  • Simulate
  • Build
  • Validate
Read case study
  • Aerodynamics
  • Wind tunnel
  • Optimisation
02 01 REQUIREMENTpayload · endurance · mass 02 SIZEmotor · propeller · battery pack 03 TEST STANDdesigned · analysed · fabricated 04 COMPAREmeasured vs predicted REVISE

UAV propulsionJul 2024 – Apr 2025

Hybrid UAV propulsion test stand

At Avironix Drones I sized motors and battery packs for different UAVs — then designed, analysed, fabricated and tested a propulsion test rig to check those choices on the bench. It became my BE thesis.

Role
Engineering intern, Avironix Drones
Thesis
Hybrid UAV Propulsion System Test Stand
  • Simulate
  • Build
  • Validate
Read case study
  • Propulsion
  • Battery sizing
  • Test rig
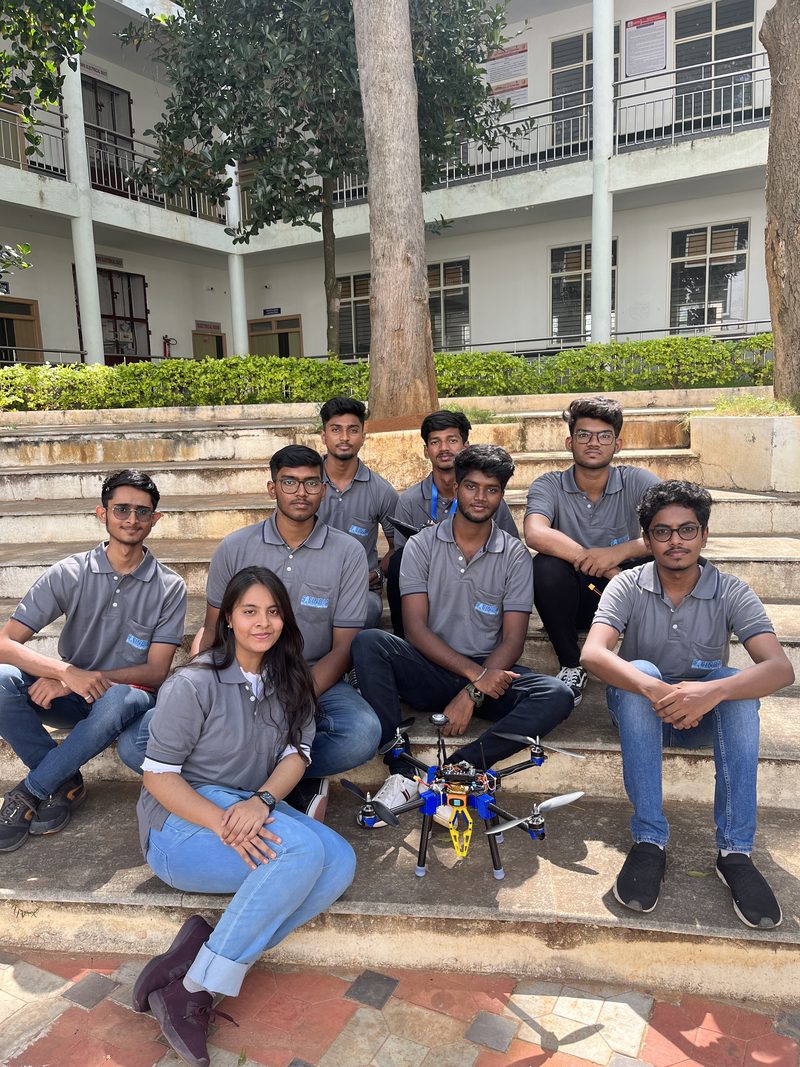
03 Team Delta members seated on steps with their multirotor drone

Turbonites Team Delta — UAV

Autonomous UAVsMar 2023 – Apr 2025

Team Delta & the Falcon multirotors

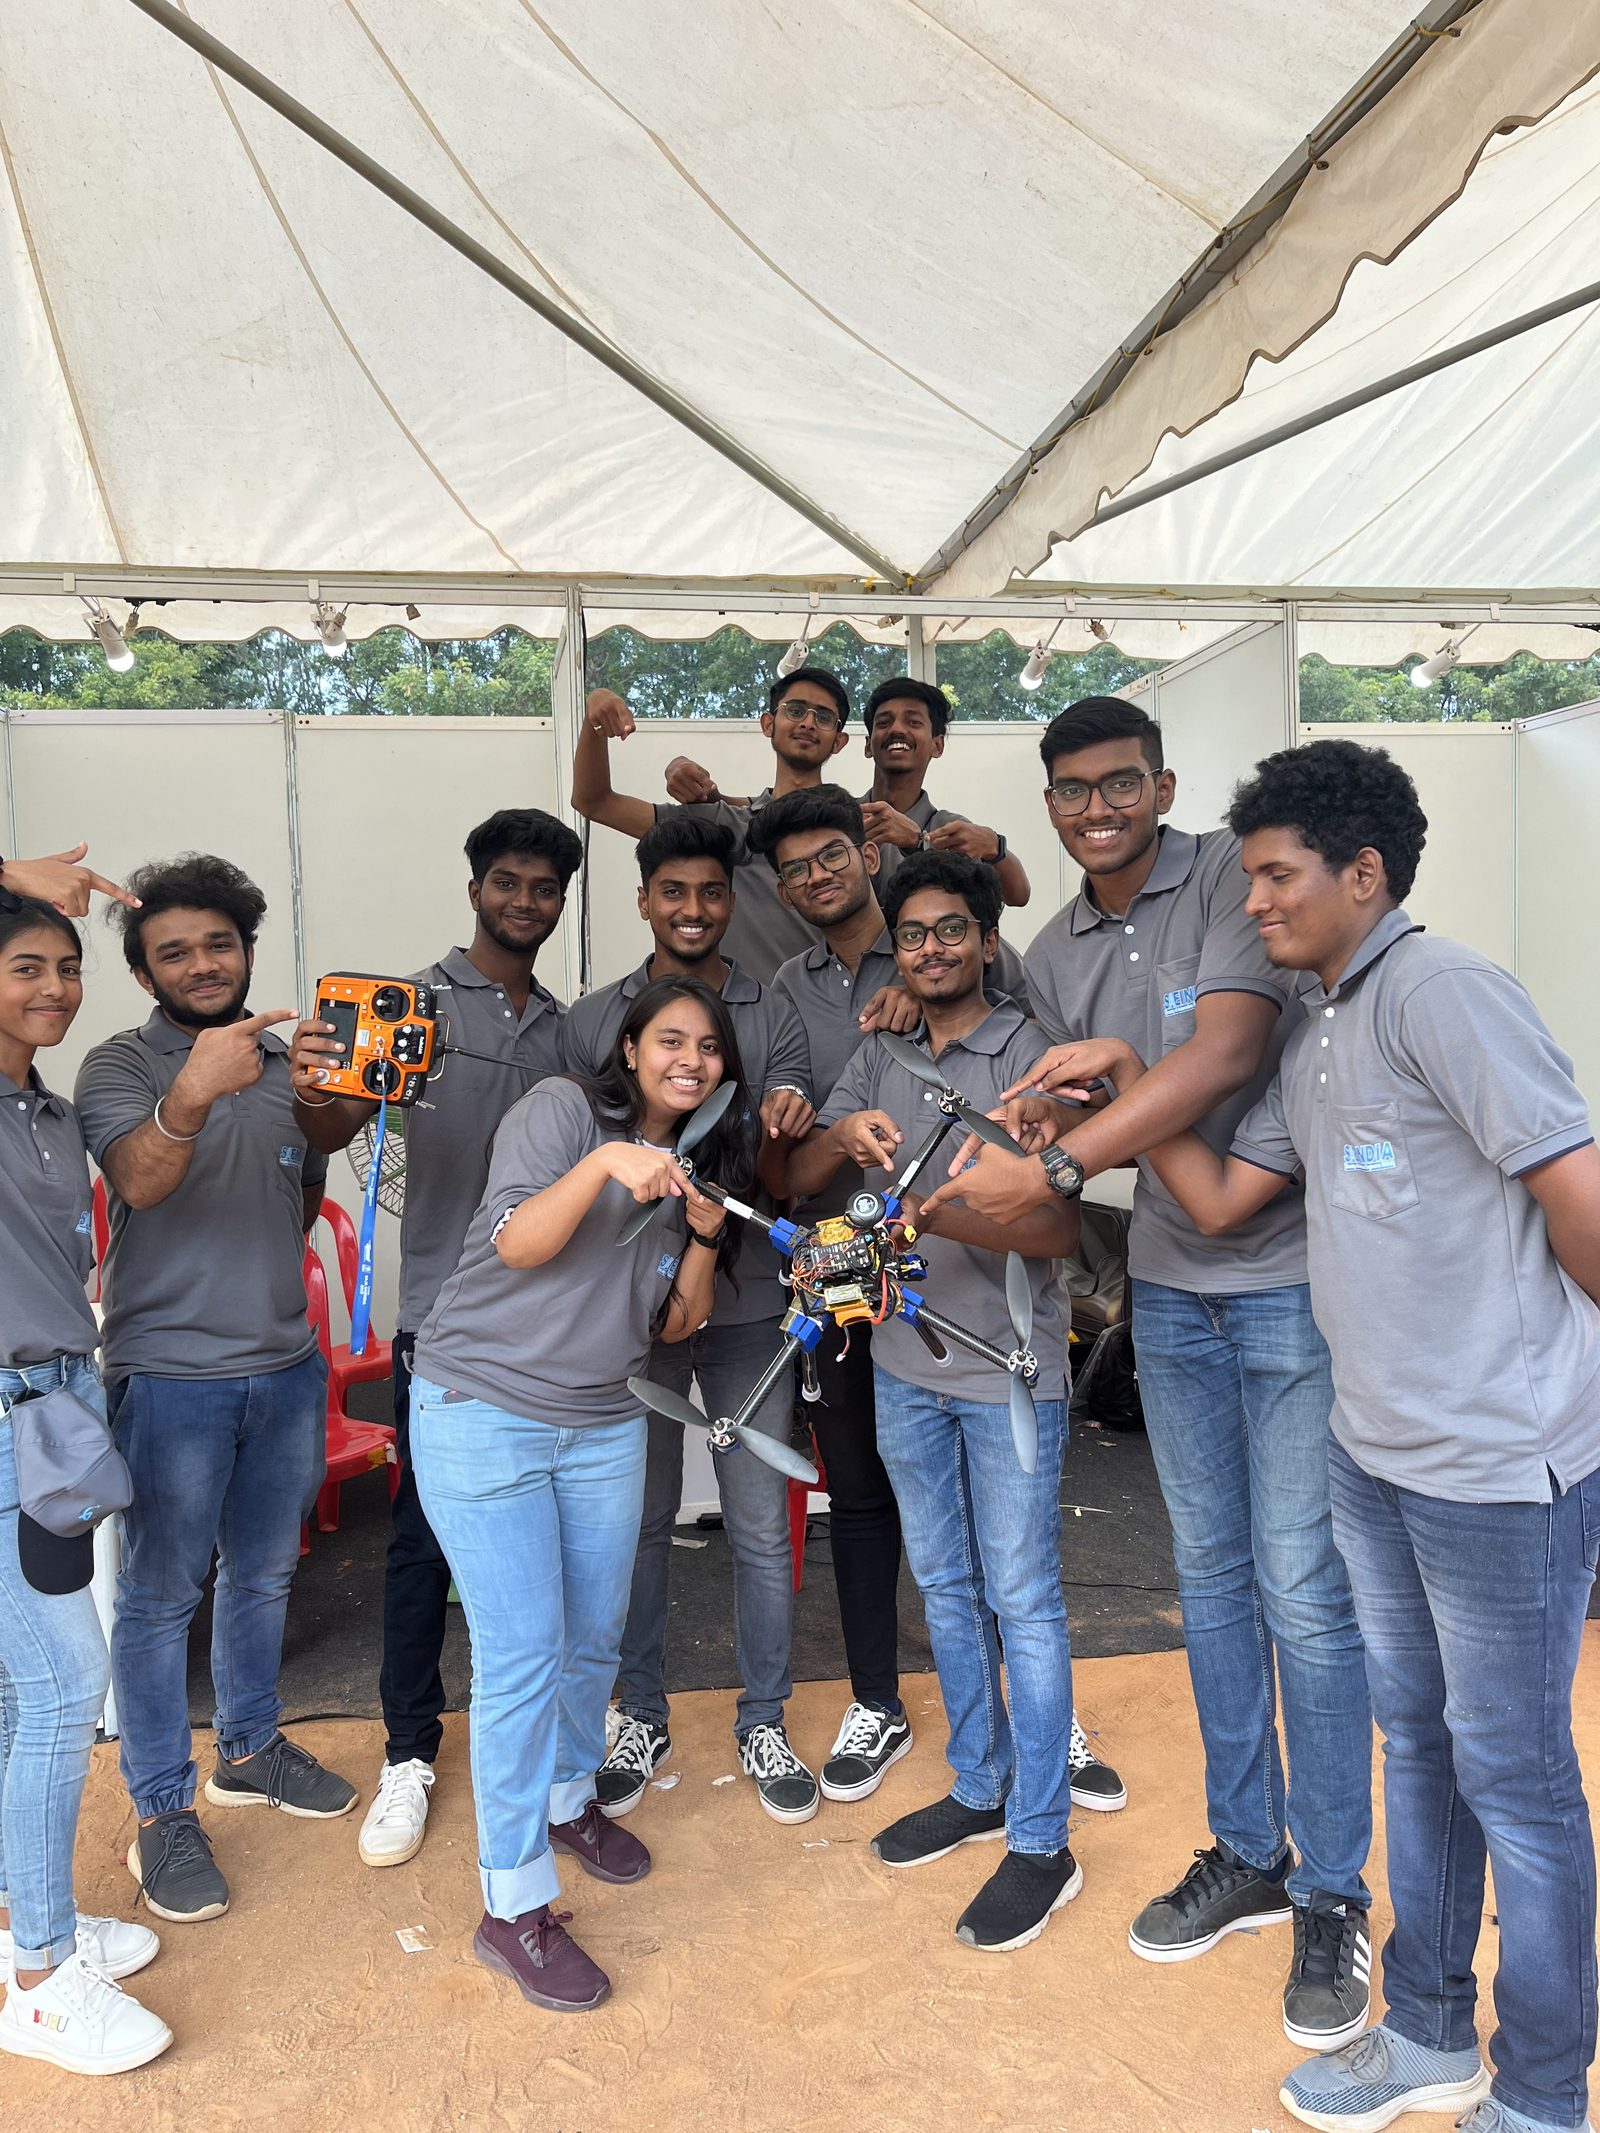
Founded and captained Turbonites Team Delta, an interdepartmental UAV team of 20. We designed mission-specific autonomous multirotors for AeroTHON and ADDC — payload drops, computer vision, long endurance.

Role
Founder & captain
Result
2nd, Best Design Report — ADDC 2024
  • Simulate
  • Build
  • Validate
Read case study
  • Leadership
  • PID tuning
  • Mission planning
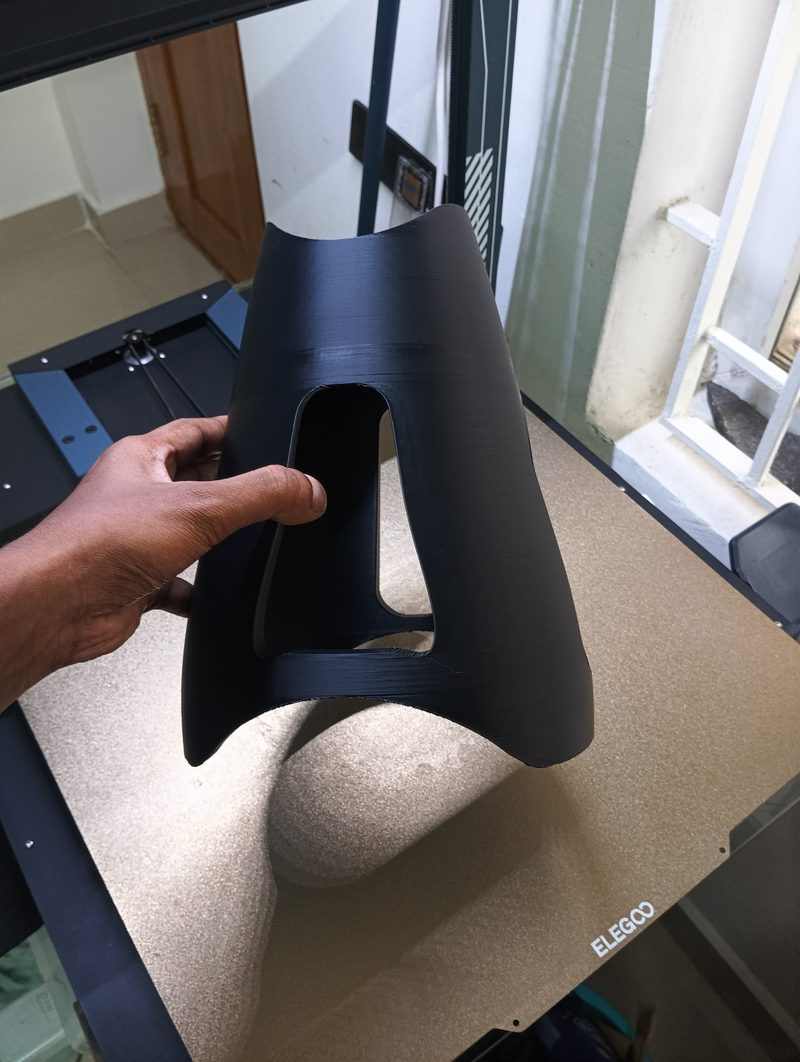
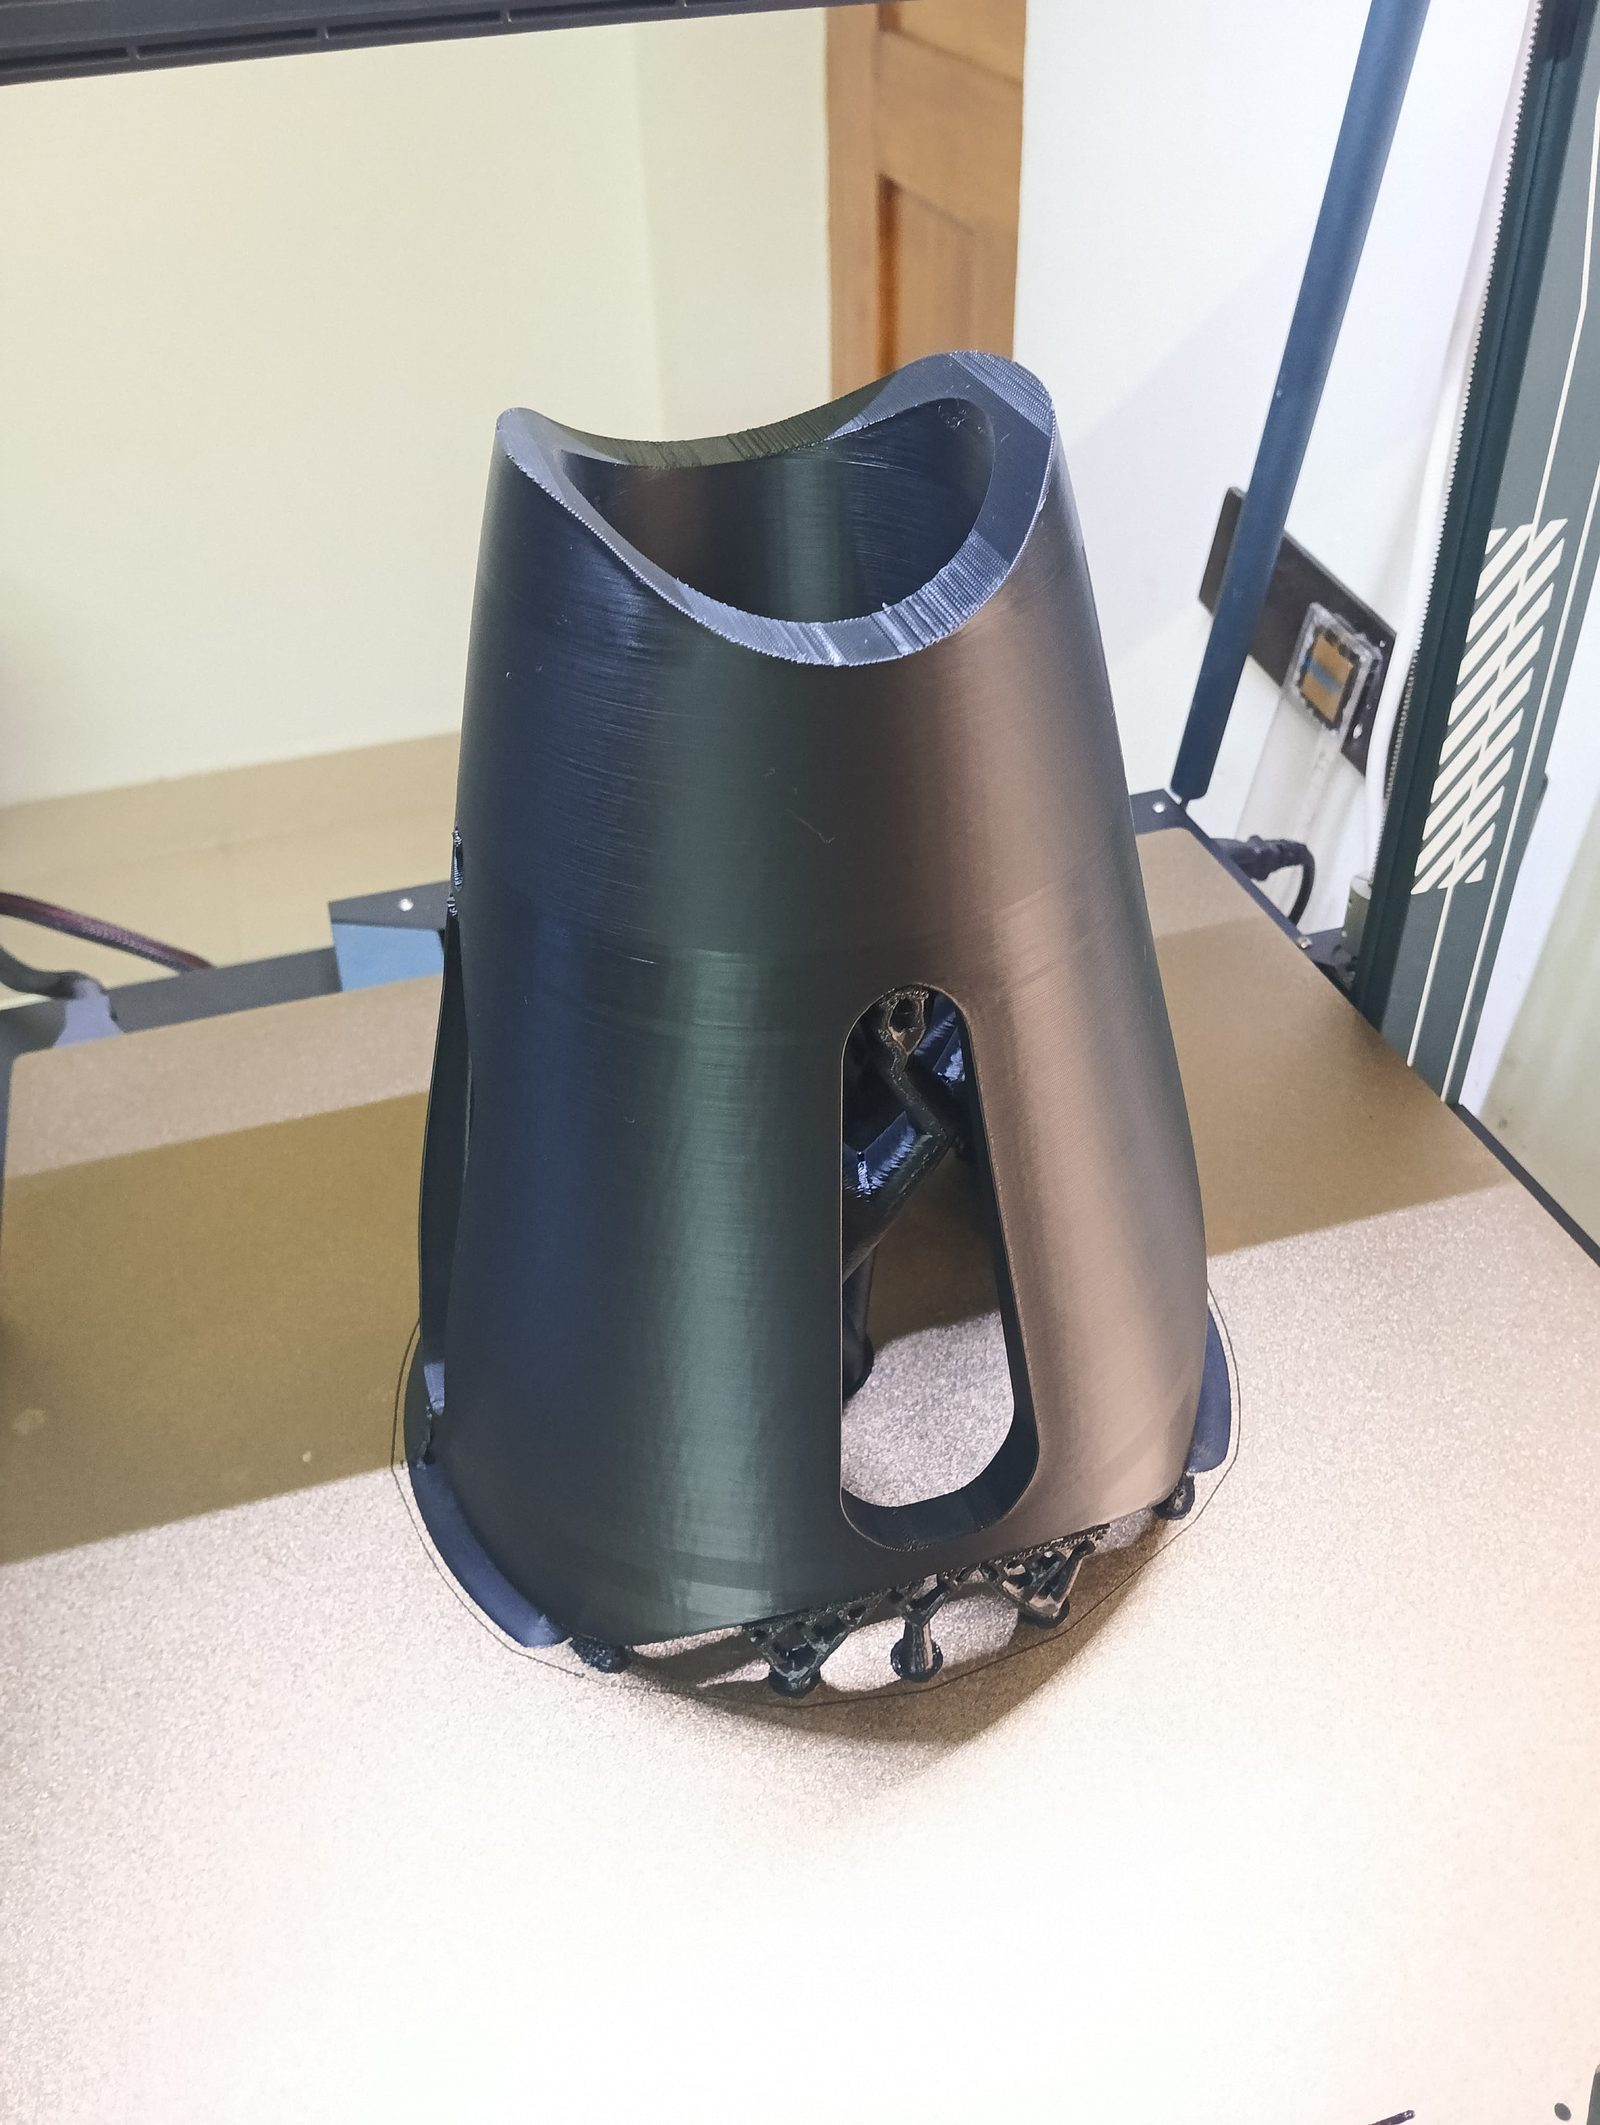
04 Large black 3D-printed cowling held above the printer bed

Large-format functional print

Additive manufacturingMay 2024 – present

XTRUDE3D — functional 3D printing

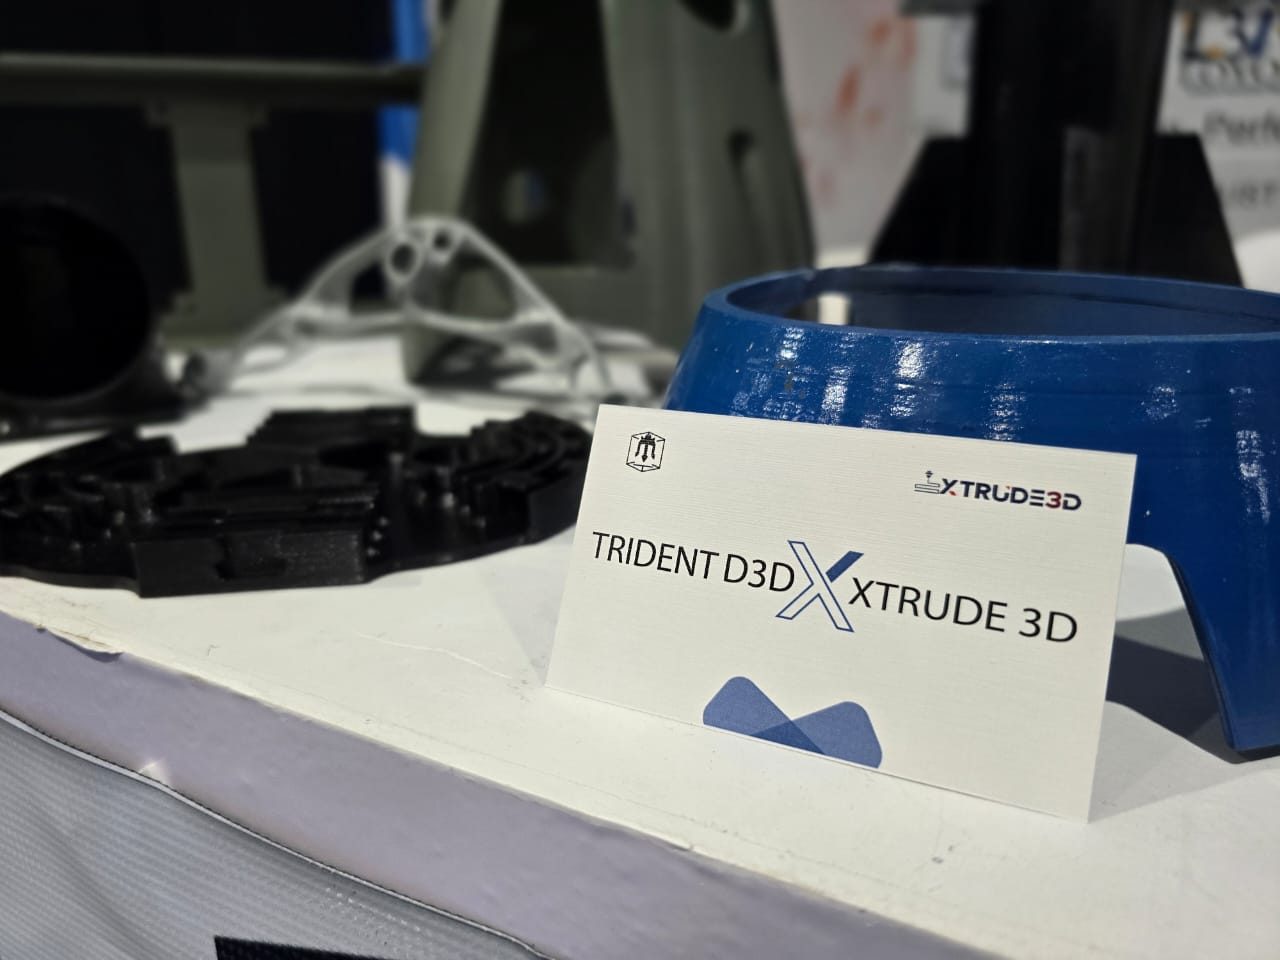
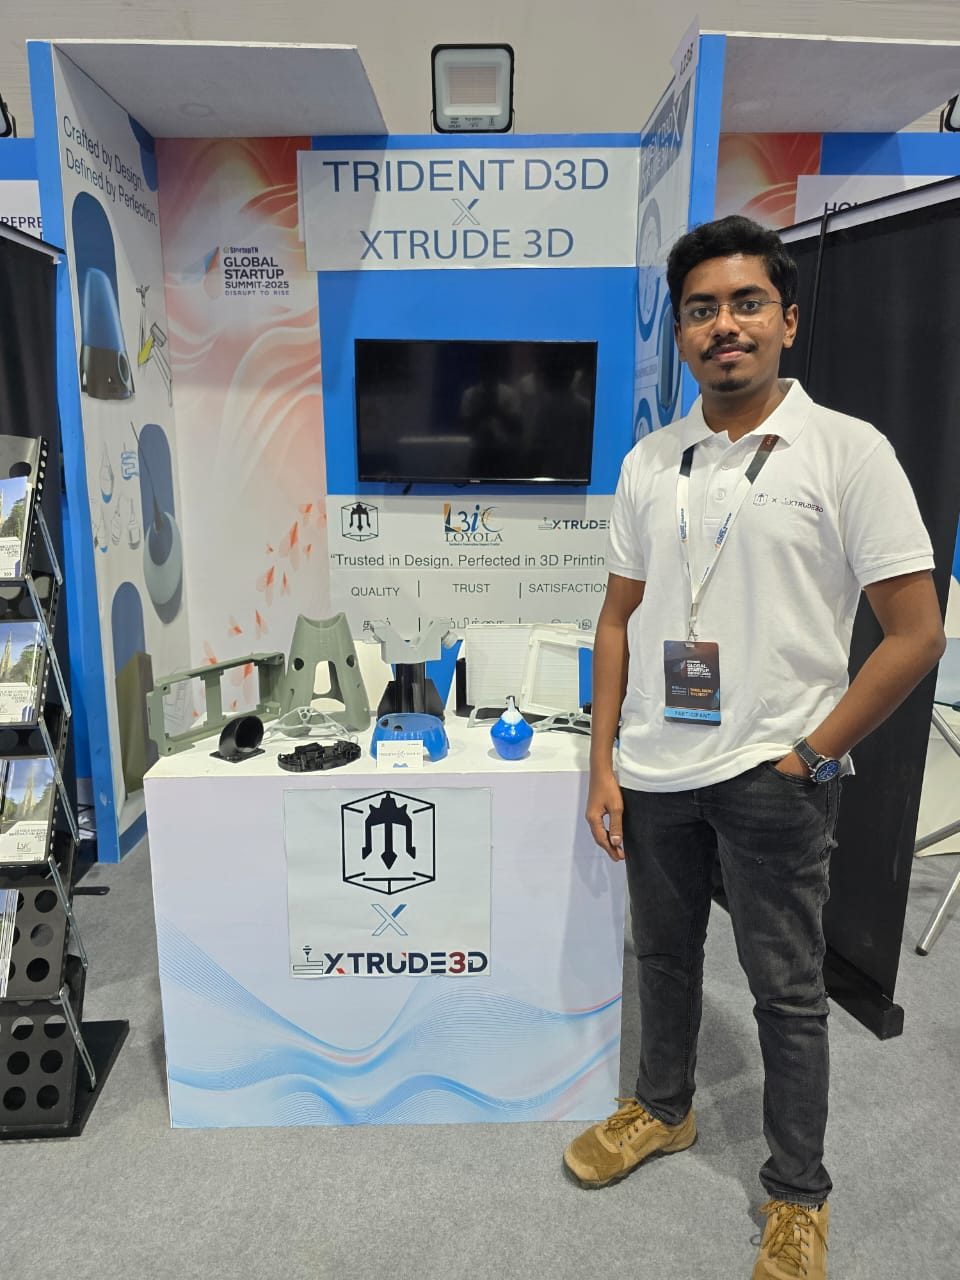
A startup I founded and run, supplying functional 3D printing and prototyping to industrial and engineering projects — parts that carry load and fit an assembly, not display pieces.

Role
Founder & owner
Credentials
National Rank 2 — 3D printing & CAM
  • Simulate
  • Build
  • Validate
Read case study
  • DfAM
  • FDM
  • Prototyping
03

Project index

Filter by discipline

  • 2024–25Vehicles

    E-Kart powertrain

    Led the powertrain department: motor and battery sizing, powertrain design and calculations, and integrated electrical safety features.

    Head of Powertrain · Turbonites

  • 2023–24Robotics

    Lumineer — autonomous lunar rover

    Designed a fully autonomous lunar rover with sample collection and drop capability.

    IRoC-U 2024 — ISRO Robotics Challenge, U R Rao Satellite Centre

  • 2023–24Robotics

    High-speed line follower

    Designed and built a high-speed line-following robot with Team McQuade.

    Universal Robo League — national level

  • 2023Robotics

    AGV with obstacle avoidance

    My first competition build: an automated guided vehicle with obstacle avoidance, with Team Tronics.

    Robo Rumble 2023

  • 2023Electronics

    Rapidly deployable surveillance system

    ESP32-based wireless micro camera, viewable from any browser on the local Wi-Fi network. Designed and fabricated with Team Tronics.

    1st place — CARPE DIEM hackathon, LICET

  • 2023–24Electronics

    Model-rocket flight computer

    Arduino Pro Mini flight computer with an MPU6050 accelerometer/gyroscope and a BMP280 barometer.

    Personal project

  • 2022–23Vehicles

    Baja ATV

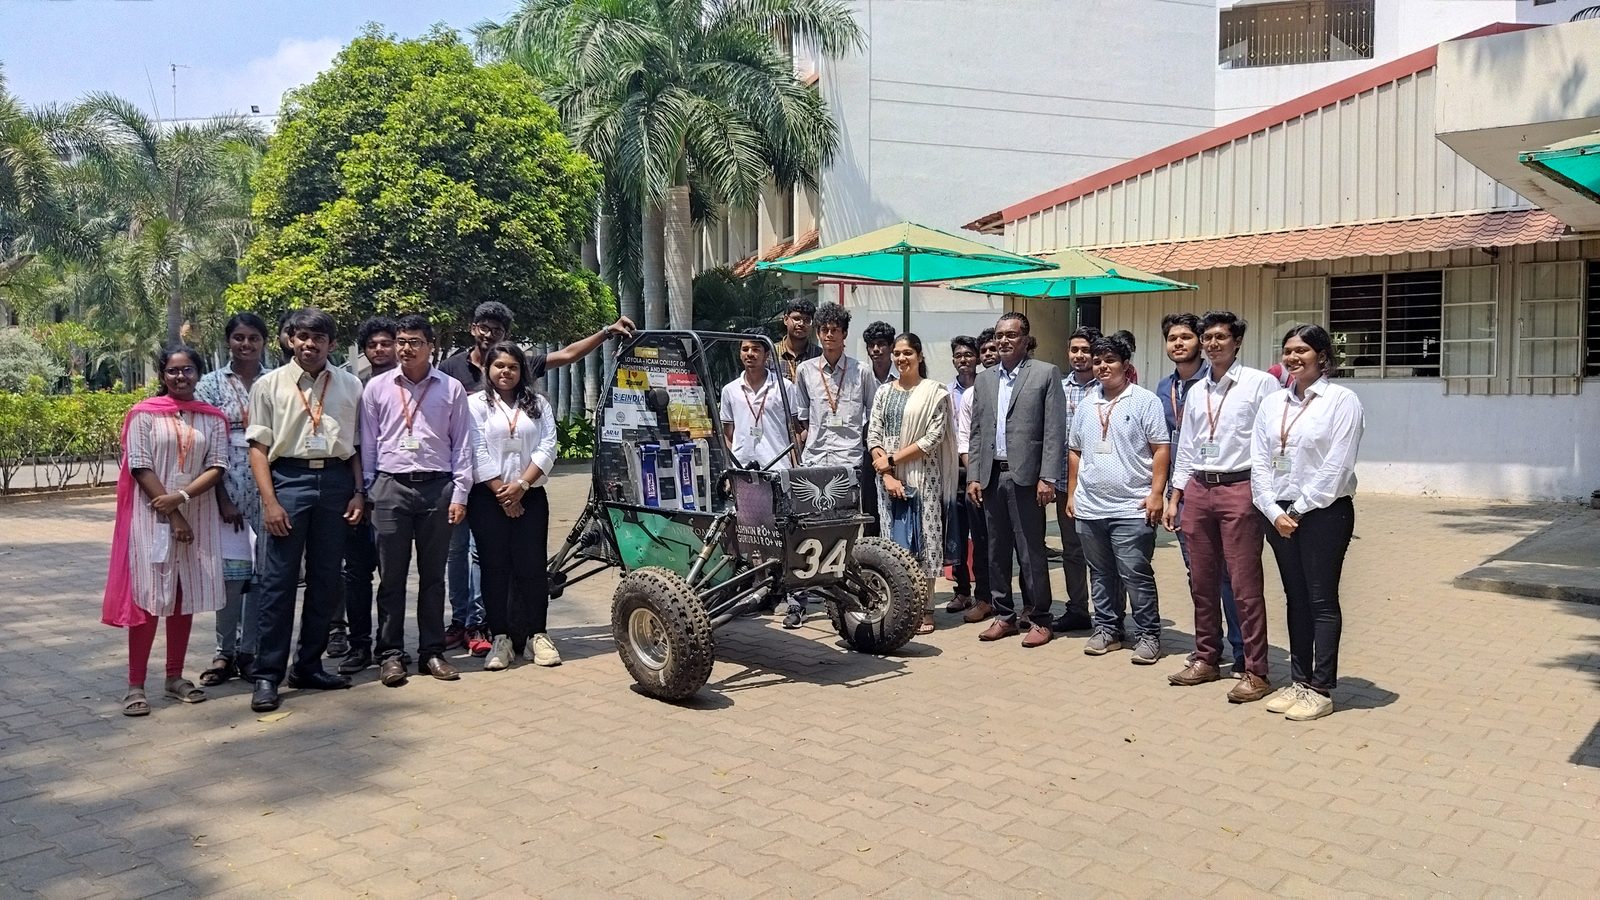
    Procurement, frame fabrication, vehicle wiring and electrical safety, powertrain assembly. Brought in 5S workshop organisation; pit manager at competition.

    Powertrain member · Turbonites

04

Experience

2021 → now

Most of it ran in parallel. In 2024 I was interning on UAV propulsion, running a 3D-printing business, captaining a drone team and heading an E-Kart powertrain — at the same time.

Jul 2024 – Apr 2025

Engineering Intern

Avironix Drones

  • Worked on UAV propulsion and power systems.
  • Sized and selected motors and battery packs for different UAVs.
  • Designed, analysed, fabricated and tested a propulsion-system test rig.
  • Wrote it up as my BE thesis: Design and Development of Hybrid UAV Propulsion System Test Stand.
May 2024 – present

Founder & Owner

XTRUDE3D

  • Started a business providing functional 3D printing and prototyping.
  • Serves industrial and engineering projects — parts with a job to do.
  • Runs the whole chain: client brief, design for the process, material, print, delivery.
Mar 2023 – Apr 2025

Founder & Captain

Turbonites Team Delta — UAV · LICET

  • Formed a competitive interdepartmental UAV team of 20.
  • Designed mission-specific autonomous multirotors: Falcon 1, 2 and 3.
  • Competed nationally at AeroTHON 2023, 2024 and 2025 and ADDC 2024.
  • 2nd Prize, Best Design Report — SAEISS ADDC 2024.
Apr 2024 – Feb 2025

Head of Powertrain

Turbonites — E-Kart · LICET

  • Managed the powertrain department.
  • Motor and battery sizing; powertrain design and calculations.
  • Integrated electrical safety features.
Aug 2022 – Mar 2023

Powertrain Member

Turbonites — Baja ATV · LICET

  • Component procurement, frame fabrication, vehicle wiring and electrical safety.
  • Implemented 5S workplace organisation.
  • Assisted powertrain assembly; pit manager during competitions.
Across all of it

What running teams taught me

Turbonites · LICET

  • My time on the Baja team showed me how a competitive technical team really runs — including the parts nobody writes down.
  • A UAV lecture in second year turned into a team of my own.
  • Founding one meant recruiting across departments and training newcomers through drone-design workshops.
Also: societies, events & extra-curricular
2022 – 2024

Workshops & stalls

Ran drone-design workshops; set up a 3D-printing stall to raise money for charity and a BBQ stall at the college symposium.

Aug – Sep 2023

Sponsorship team — Engenia 2023

Found and coordinated sponsors; arranged stalls with food partners.

Feb – Jun 2022

Science Club core team

Organised and hosted STEM events and quizzes.

2021 – 2025

LICET culturals — Engenia

Trained juniors for off-stage events. 1st and 3rd in JAM (speaking); 3rd in short film.

2021 – 2025

Parade commander & chess

Department parade commander for sports day — drill, discipline and presentation. Department chess team.

05

Recognition

Awards · judging · mentoring
  1. 1st Prize — Best Payload Mechanism Design

    ADDC 2025, SAEISS. With Team Phoenix — calibration, troubleshooting and test flights.

    National
  2. National Rank 2 — CAM Competition

    NLSC, SAEISS. Showed distinctive 3D-printing methods and features; 1st place at both zonal and college level.

    National
  3. 2nd Prize — Best Design Report

    SAEISS ADDC 2024 — Autonomous Drone Development Challenge. An industry-standard design report for Team Delta's entry.

    National
  4. National Rank 2 — 3D Printing Competition

    NLSC, SAEISS. 1st place at both zonal and college level.

    National
  5. 3rd Prize — Automotive Quiz

    NLSC, SAEISS.

    Zonal
  6. 1st Place — CARPE DIEM Hackathon

    LICET. Designed and fabricated a rapidly deployable surveillance system.

    College
  7. State 1st — Ascent science talent exam

    Inter-school competition, statewide.

    State
  8. Winner — SCI-TECH Science Expo

    A piezoelectric shoe that charges a phone while jogging.

    Expo

Judging & mentoring

Invited roles
  • Judge

    Torq2k25 — Shark Tank

    Invited judge for the shark-tank event at LICET's technical symposium.

  • Judge

    Envision'25 hackathon

    Invited judge for the interdepartmental hackathon run by LICET's Institution's Innovation Council.

  • Mentor

    Techie Trackers — Techno Teen'22

    Guided the development of an autonomous railway-track maintenance rover.

  • Mentor

    Power House — Envision'24

    Guided Dynami-Shoe, a piezoelectric energy-harvesting shoe that powers small electronic devices.

06

Education & toolkit

Degrees · certifications · skills

MEng Mechanical & Manufacturing Engineering

Dublin City University — Major in Simulation-Driven Design

Thesis · in progressSimulation of the aerodynamic interaction of an aerofoil under different wind loads, for a novel wind energy system.
2026 – present● Current

BE Mechanical Engineering — First Class

Loyola-ICAM College of Engineering and Technology (LICET), Chennai

ThesisDesign and Development of Hybrid UAV Propulsion System Test Stand.
2021 – 2025Chennai, IN

Certifications

6 credentials
  • SOLIDWORKS Electrical Associate

    SOLIDWORKS certification

  • SOLIDWORKS Additive Manufacturing Associate

    SOLIDWORKS certification

  • Design Principles for 3D Printed Parts

    Prusa Research

  • UAV in Engineering Applications

    NPTEL

  • IELTS Academic — Band 8

    English proficiency

  • Upper Intermediate English

    British Council

Toolkit

Highlighted = certified or core

Design & simulation

  • SOLIDWORKS
  • Simulation-driven design
  • CAD / CAE
  • Aerodynamic analysis
  • Design optimisation
  • System design

Manufacturing

  • FDM 3D printing
  • Design for AM
  • Slicing software
  • Rapid prototyping
  • Fabrication
  • 5S

UAV & propulsion

  • Propulsion sizing
  • Battery-pack sizing
  • Test-rig design
  • Calibration & PID tuning
  • Mission planning
  • GCS software

Electronics

  • Arduino
  • ESP32
  • IMU & barometer integration
  • Vehicle wiring
  • Electrical safety

People

  • Team building
  • Leadership
  • Presentation
  • Communication
  • Mentoring
  • Sponsorship
07

About

Chennai → Dublin
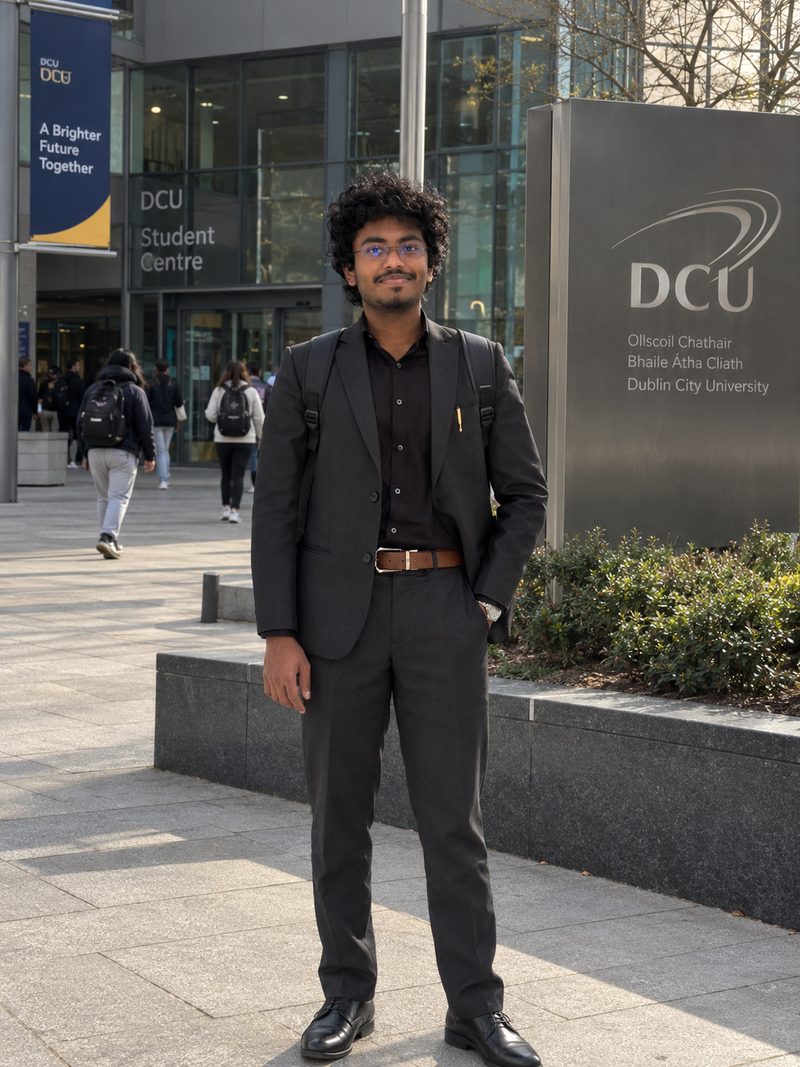
Samuel Wesley Mondal in a suit outside the Dublin City University Student Centre
Dublin City University

Engineering, for me, is less a degree than a habit: find a real problem, get the right people around it, and build something that works.

I grew up in Chennai and took a First Class BE in Mechanical Engineering at LICET. Most of those four years happened outside the lecture hall — on a Baja team, founding a UAV team, running a 3D-printing business and interning on drone propulsion at Avironix.

Now I'm in Dublin doing an MEng at DCU with a major in simulation-driven design, adding modelling rigour to the building habit. I'm competitive by nature, and I like bringing together people with the same mindset to solve a problem properly.

Based in
Dublin, Ireland
From
Chennai, India
Studying
MEng, Dublin City University
English
IELTS Academic Band 8

Off the clock

  • Unmanned aerial systems
  • Aerospace
  • Physics
  • Chess
  • Speed cubing
  • MMA
  • Camping & fishing

Find me online
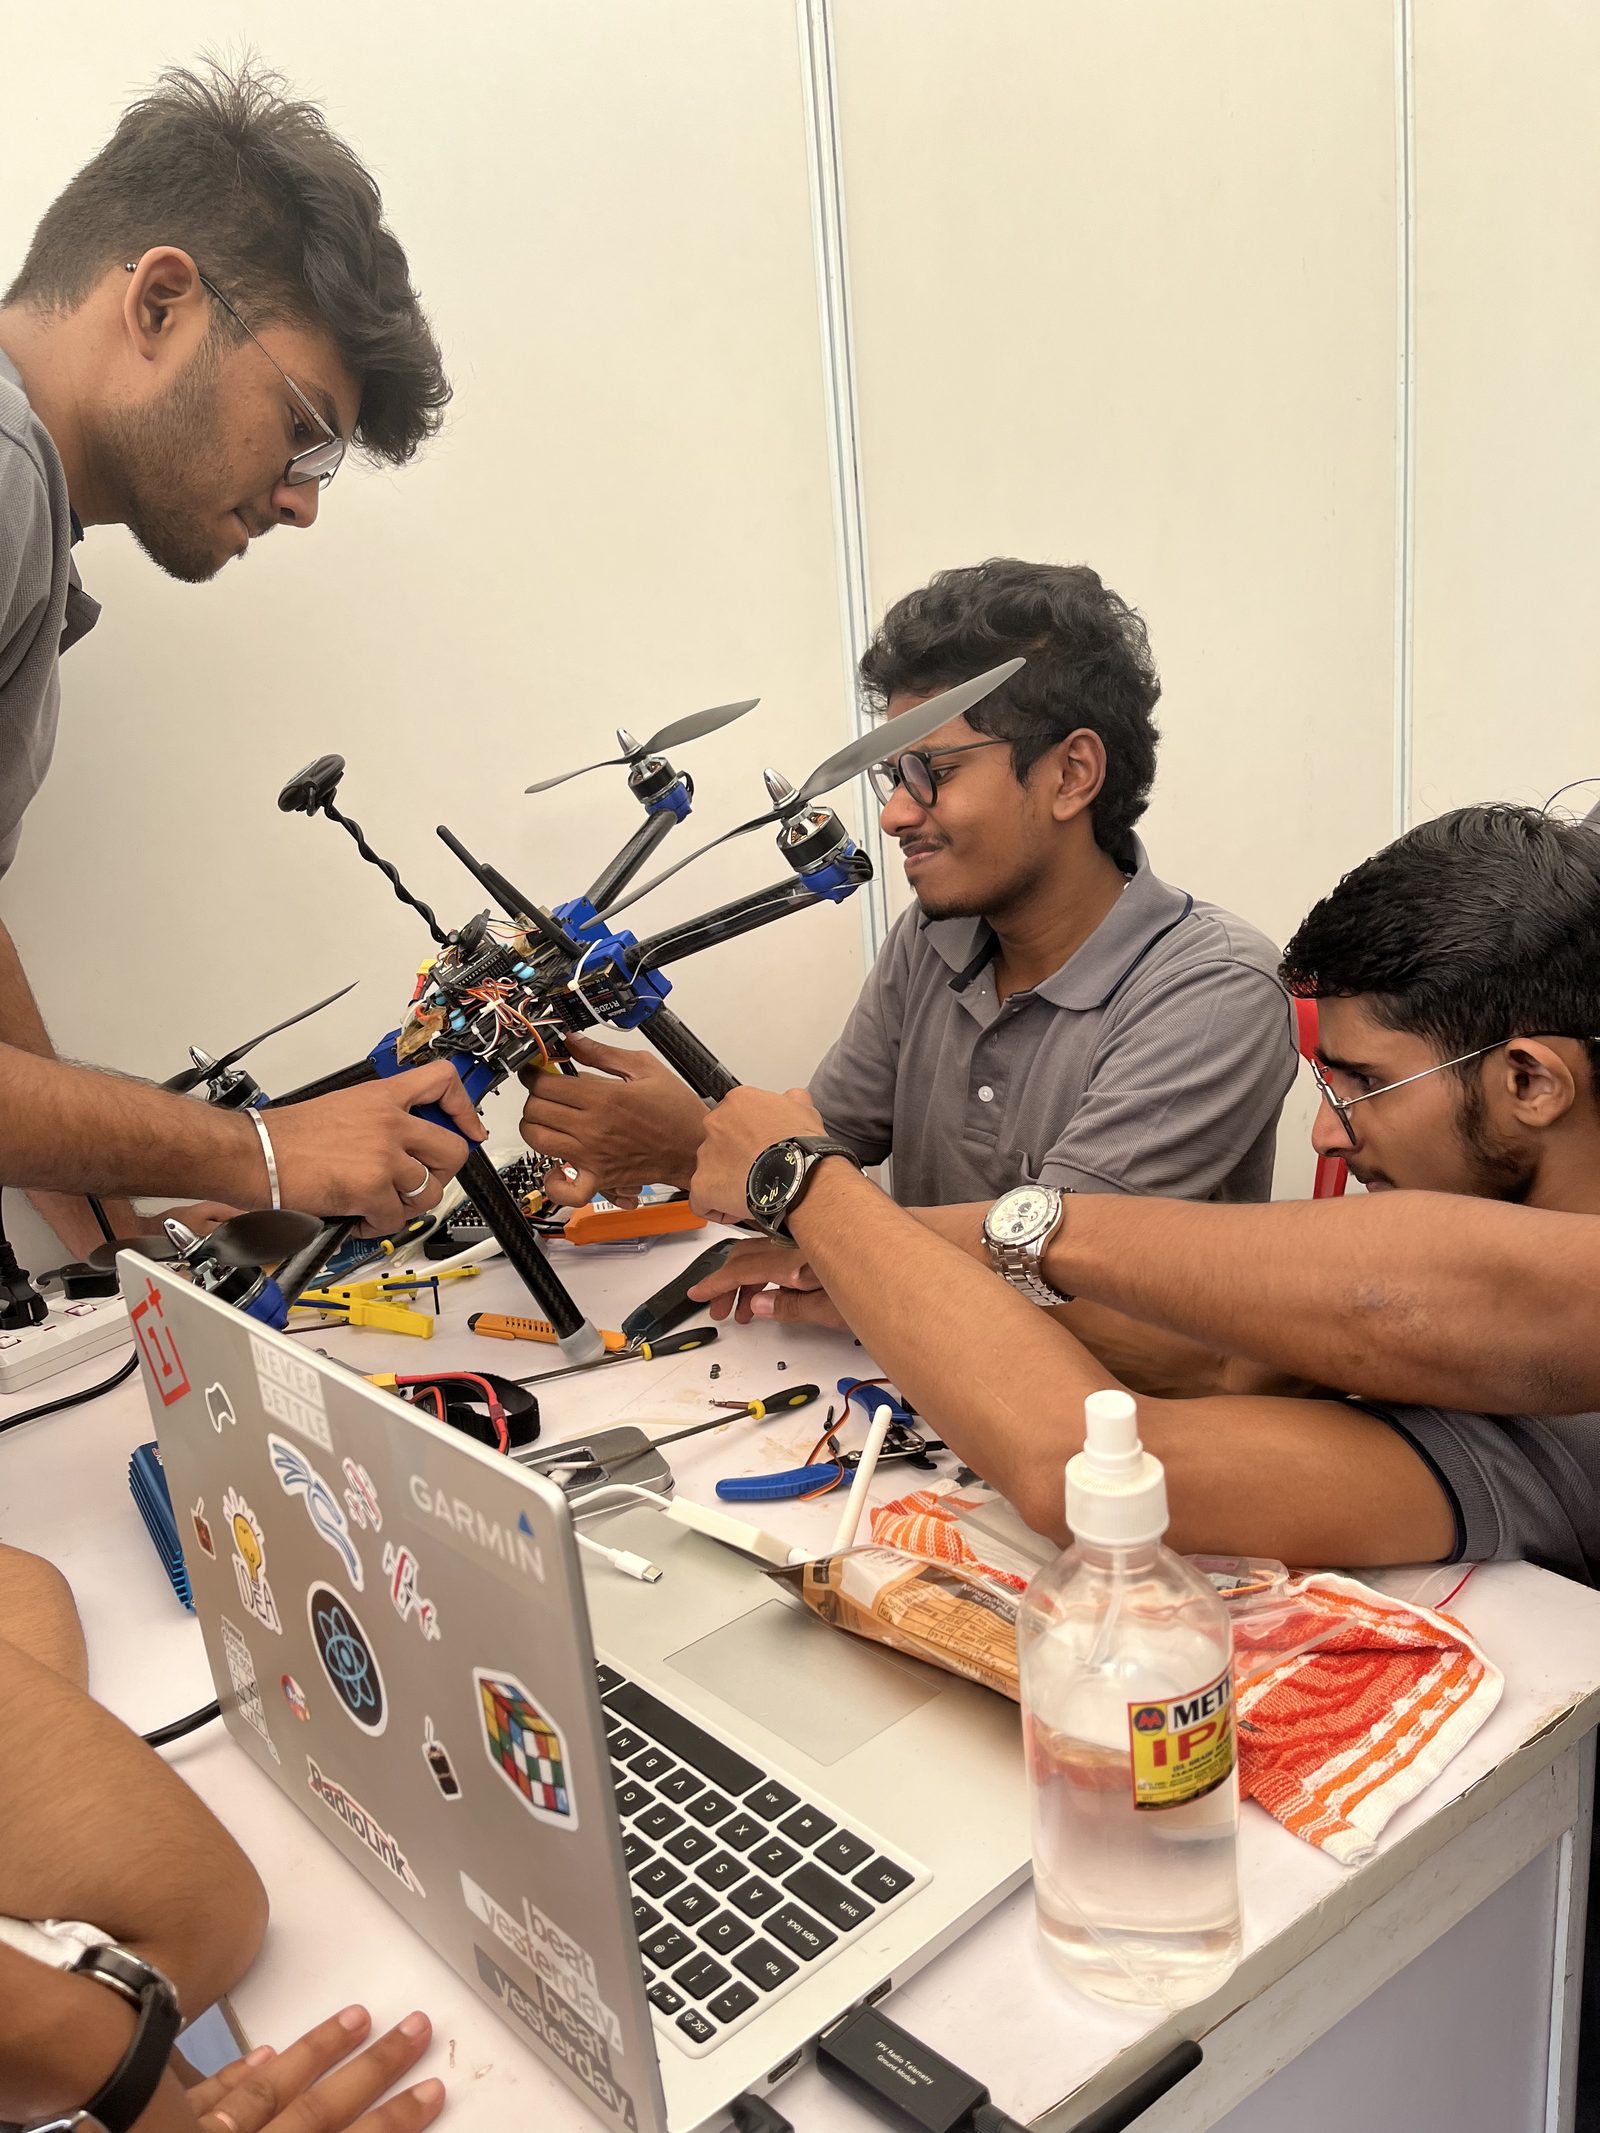
Team of twelve with their drone under a competition marquee Baja team lined up with their green ATV Four people at the XTRUDE3D exhibition stand Three people assembling and wiring a hexacopter at a workbench Black 3D-printed conical duct on the printer bed 3D-printed parts next to an XTRUDE3D business card Samuel Wesley Mondal standing at the XTRUDE3D exhibition stand

Have a problem that needs a model and a prototype?

I'm looking for internships and placements in mechanical design, simulation and UAV systems. Email is the fastest way to reach me.

Currently
MEng, Dublin City UniversitySimulation-Driven Design
Looking for
Internship / placementMechanical design · simulation · UAV
Based in
Dublin, IrelandLocal time —
Languages
EnglishIELTS Academic Band 8

Write to me

~1 minute

Opens your email app with this filled in. Nothing is stored or sent by this site.

Case study 01 / 04

Wind energyJan – Apr 2026

H-type Darrieus vertical-axis wind turbine

A straight-bladed Darrieus rotor, taken from design and analysis through optimisation to wind-tunnel testing. The brief set two objectives — and the second is what this whole portfolio is about.

Scope
Design, analysis, optimisation, experimental validation
Period
Jan – Apr 2026
Test
Wind tunnel, varying loads
Loop
  • Sim
  • Build
  • Test

The brief

  1. Maximise power output under varying loads.
  2. Minimise the deviation between predicted and experimental performance.

The first objective is a design problem. The second is a modelling problem: it asks how good the prediction was, not just how good the turbine was.

Why it's hard

An H-rotor blade never sits at one angle of attack. As it travels round, the flow it sees swings through a large range every revolution — and at low tip-speed ratios that swing goes well past the angle where a static aerofoil stalls. Move the slider.

2.5

Peak α — · Beyond ±13° for — of each turn · Relative speed W/U∞ from —

Geometric angle of attack for one blade, α = atan[sin θ / (λ + cos θ)], ignoring induced velocity. Shaded band: an illustrative static-stall range of ±13°. Textbook blade kinematics to show the problem — not measured data from this project.

Method

  1. 01 Simulate

    Analysed the rotor and optimised the design for power output across the load range.

  2. 02 Build

    Produced the rotor as a physical test article for the tunnel.

  3. 03 Validate

    Tested under varying loads and compared measured performance against the prediction.

Rotor

U∞ ω λ = ωR / U∞

Straight blades on struts, turning about a vertical shaft: the rotor accepts wind from any direction, at the cost of the cyclic loading shown above. Schematic only.

Connects to

This sits right next to my MEng thesis at DCU — simulating the aerodynamic interaction of an aerofoil under different wind loads, for a novel wind energy system.

  • Aerodynamics
  • VAWT
  • Darrieus
  • Wind tunnel
  • Optimisation
  • Validation

Want the detail behind this project?

Ask me about it

Case study 02 / 04

UAV propulsionJul 2024 – Apr 2025

Hybrid UAV propulsion test stand

Engineering intern, Avironix Drones · BE thesis, LICET

Sizing a UAV's propulsion and power system is a prediction built from datasheets and calculations. At Avironix I did that sizing for different aircraft — then designed, analysed, fabricated and tested a propulsion test rig so the predictions could be checked on the bench before anything flew.

Role
Engineering intern
Period
Jul 2024 – Apr 2025
Output
Test rig + BE thesis
Loop
  • Sim
  • Build
  • Test

The problem

Motor, propeller and battery are chosen together, and every choice trades against the others — endurance against payload against mass against thermal headroom. Datasheet figures are measured under someone else's conditions. A test stand is how you find out what your combination actually delivers.

What I did

  • Sized and selected motors and battery packs for different UAVs.
  • Designed and analysed a propulsion-system test rig.
  • Fabricated the rig and tested propulsion configurations on it.
  • Wrote it up as my undergraduate thesis: Design and Development of Hybrid UAV Propulsion System Test Stand.

Method

01 REQUIREMENTpayload · endurance · mass 02 SIZEmotor · propeller · battery pack 03 TEST STANDdesigned · analysed · fabricated 04 COMPAREmeasured vs predicted REVISE
  1. 01 Simulate

    Size motor, propeller and battery pack from the requirement and datasheets.

  2. 02 Build

    Design, analyse and fabricate the test rig.

  3. 03 Validate

    Bench-test the combinations and compare against the sizing.

  • Propulsion
  • Battery sizing
  • Test-rig design
  • Fabrication
  • Hybrid power

Want the detail behind this project?

Ask me about it

Case study 03 / 04

Autonomous UAVsMar 2023 – Apr 2025

Team Delta & the Falcon multirotors

Founder & captain, Turbonites Team Delta — UAV

In my second year I formed Team Delta, a competitive interdepartmental UAV team, and captained it for two years. Twenty people, three mission-specific aircraft, and national competitions where the drone either completes the mission or it doesn't.

Role
Founder & captain
Team
20 members, interdepartmental
Competitions
AeroTHON 2023–25 · ADDC 2024
Loop
  • Sim
  • Build
  • Test
Team of twelve with their drone under a competition marquee

The fleet

  • Mar 2023 – Nov 2024

    Falcon 1

    High-endurance multirotor with payload-dropping capability.

    • AeroTHON 2023
  • Dec 2023 – Apr 2025

    Falcon 2 & 3

    Autonomous multirotors with payload dropping and computer vision.

    • ADDC 2024
    • AeroTHON 2024
    • AeroTHON 2025

My part

  • Formed and led the team: 20 members from across departments.
  • Worked extensively on the aircraft design, optimising propulsion and power systems.
  • Calibration and PID tuning; mission planning.
  • Wrote the industry-standard design report for ADDC 2024.
  • Ran drone-design workshops to bring new people in.

Results

  • 2nd Prize — Best Design Report, SAEISS ADDC 2024.
  • Also: 1st Prize — Best Payload Mechanism Design, ADDC 2025, as part of Team Phoenix (calibration, troubleshooting, test flights).

Gallery

  • Leadership
  • Multirotor design
  • Propulsion & power
  • PID tuning
  • Mission planning
  • Computer vision

Want the detail behind this project?

Ask me about it

Case study 04 / 04

Additive manufacturingMay 2024 – present

XTRUDE3D — functional 3D printing

Founder & owner

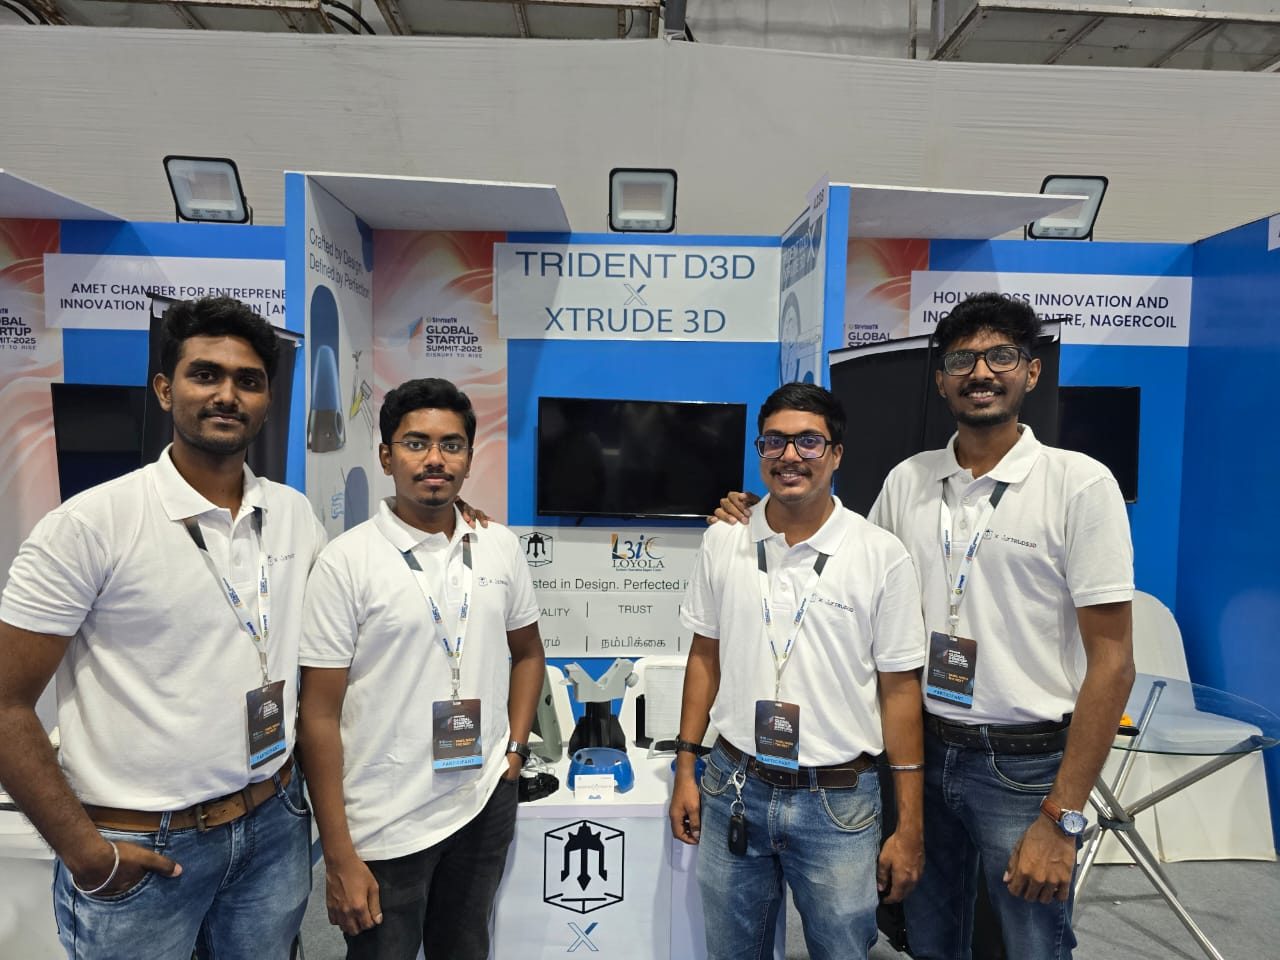
A startup that provides functional 3D printing and prototyping for industrial and engineering projects. Functional is the operative word: parts that carry load, fit an assembly and survive use.

Role
Founder & owner
Since
May 2024
Clients
Industrial & engineering projects
Loop
  • Sim
  • Build
  • Test
Four people at the XTRUDE3D exhibition stand

What it does

Running it means owning the whole chain: the client's problem, designing the part for the process, choosing the material, printing it, and standing behind it afterwards.

Credentials

  • National Rank 2 — 3D Printing Competition, SAEISS NLSC (2023), with 1st place at zonal and college level.
  • National Rank 2 — CAM Competition, SAEISS NLSC (2024).
  • SOLIDWORKS Additive Manufacturing Associate.
  • Design Principles for 3D Printed Parts — Prusa Research.

Gallery

  • DfAM
  • FDM
  • Functional parts
  • Prototyping
  • Client delivery

Need a functional part printed?

Get in touch
Esc
↑↓navigateEnteropenEscclose